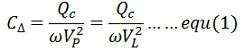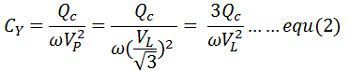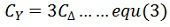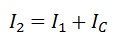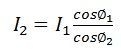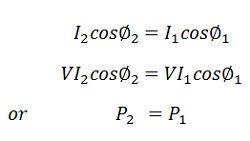Friday, 24 May 2019

Difference between Induction Motor and Synchronous Motor

Difference between Induction Motor and Synchronous Motor

Difference Between Induction and Synchronous Motor is explained with the help of various factors, like the type of excitation used for the machine. The Speed of the motor, starting and operation, the efficiency of both the motors, its cost, usage, and applications. frequency.
BASIS OF DIFFERENCESYNCHRONOUS MOTORINDUCTION MOTOR
Type of ExcitationA synchronous motor is a doubly excited machine.An induction motor is a single excited machine.
Supply SystemIts armature winding is energized from an AC source and its field winding from a DC source.Its stator winding is energized from an AC source.
SpeedIt always runs at synchronous speed. The speed is independent of load.If the load increased the speed of the induction motor decreases. It is always less than the synchronous speed.
StartingIt is not self starting. It has to be run up to synchronous speed by any means before it can be synchronized to AC supply.Induction motor has self starting torque.
OperationA synchronous motor can be operated with lagging and leading power by changing its excitation.An induction motor operates only at a lagging power factor. At high loads the power factor becomes very poor.
UsageIt can be used for power factor correction in addition to supplying torque to drive mechanical loads.An induction motor is used for driving mechanical loads only.
EfficiencyIt is more efficient than an induction motor of the same output and voltage rating.Its efficiency is lesser than that of the synchronous motor of the same output and the voltage rating.
CostA synchronous motor is costlier than an induction motor of the same output and voltage ratingAn induction motor is cheaper than the synchronous motor of the same output and voltage rating.
An Induction Motor is also known as Asynchronous Motor. It is so called because it never runs at synchronous speed. i.e., Ns = 120f/P. The induction motor is most widely used motor in all domestic and commercial motor. The Synchronous motor always follows a synchronous speed. The speed of the rotor is maintained or synchronized with the supply current

Difference between Three Phase Induction Motor and Synchronous Motor

  • A three phase Synchronous motor is a doubly excited machine, whereas an induction motor is a single excited machine.
  • The armature winding of the Synchronous motor is energized from an AC source and its field winding from a DC source. The stator winding of Induction Motor is energized from an AC source.
  • Synchronous Motor always runs at synchronous speed, and the speed of the motor is independent of load, but an induction motor always runs less than the synchronous speed. If the load increased the speed of the induction motor decreases.
  • The induction motor has self-starting torque whereas the synchronous motor is not self starting. It has to be run up to synchronous speed by any means before it can be synchronized to AC supply.
  • A synchronous motor can be operated with lagging and leading power by changing its excitation. An induction motor operates only at a lagging power factor. At high loads, the power factor of the induction motor becomes very poor.
  • The Synchronous Motor can be used for power factor correction in addition to the supplying torque to drive mechanical loads whereas an induction motor is used for driving mechanical loads only.
  • The synchronous motor is more efficient than an induction motor of the same output and voltage rating.
  • A synchronous motor is costlier than an induction motor of the same output and voltage rating.

Synchronous Condensor

Synchronous Condensor

Synchronous Condensor is also known as Synchronous Compensator or Synchronous Phase Modifier. A synchronous condenser or a synchronous compensator is a synchronous motor running without a mechanical load. It can generate or absorb reactive volt-ampere (VAr) by varying the excitation of its field winding. It can be made to take a leading current with over-excitation of its field winding.
n such a case it delivers inductive or absorbs capacitive Volt-ampere reactive. If it is under the excited condition, it draws the lagging current and, therefore, supplies capacitive or absorbs inductive volt-ampere reactive. Thus, a current drawn by a synchronous capacitor or condenser can be varied from lagging to leading smoothly by varying its excitation.
When the motor power factor is unity, the DC excitation is said to be normal. Over-excitation causes the motor to operate at a leading power factor. Under excitation causes it to operate at a lagging power factor. When the motor is operated at no load with over-excitation, it takes a current that leads the voltage by nearly 90 degrees.
Thus, it behaves like a capacitor and under such operating conditions, the synchronous motor is called a synchronous capacitor.
Since a synchronous condenser behaves like a variable inductor or a variable capacitor, it is used in power transmission systems to regulate line voltage.

Power Factor Correction

Power Factor Correction

Definition: The power factor correction means bringing the power factor of anAC circuit nearer to one by using the equipment which absorbs or supply the reactive power to the circuit. Usually, the power factor correction can be done by using the capacitor and the synchronous motor in the circuit.The power factor correction will not change the amount of true power, but it will reduce the apparent power and the total current drawn from the load.
The phase shift between the voltage and the current of the circuit is known as the power factor. It is represented by the cosine of the angle φ. The power factor represents the fraction of total energy use for doing useful work, and the remaining energy is stored in the form of magnetic energy in the inductor and capacitor of the circuit. The value of power factor lies between -1 to +1.
The most economical value of power factor lies between 0.9 to 0.95. If the value of power factor lies below 0.8 (approx), then it draws more current from the load. The large current increases the losses and requires a large conductor, thus increases the cost of the system.The loss can be reduced by correcting the power factor of the system.

Power Factor Correction Methods

The power factor correction methods are mainly classified into two types, i.e., by using the capacitor or through the synchronous condenser.

Power Factor Correction by using Capacitor Bank

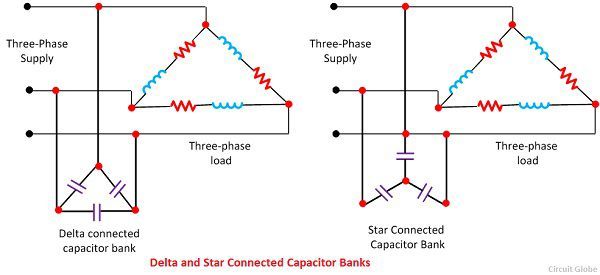
In three phase system, the power factor is improved by connecting the capacitors in star or delta. The star and delta connected banks are shown in the figure below.
power-factor-correction-imagesLet, VL = Line voltage
Vp = phase voltage
CΔ = capacitor per phase when the capacitors are connected in delta
Cy = capacitance per phase when the capacitor are connected in stars
Qc = Var rating of each phase
Delta Connection
power-factor-correction-equation-1The capacitance per phase is given by the equation
power-factor-correction-equation-2Star Connection
power-factor-correction-equation-3The capacitance per phase is expressed by the equation
power-factor-correction-equation-4From equation (1) and (2) we get
power-factor-correction-equation-5The equation (3) shows that the capacitance requires in star connection of three phase transformer is equal to three times the capacitance requires per phase when the capacitors are connected in delta. Also, the working voltage of the star connected bank is 1/√3 equal to the delta connected bank.
For these reasons, the capacitors are connected in the delta in three phase system for power factor improvement. Delta connection is also better if the capacitors are designed for higher working voltage.

Power Factor Correction by Using Synchronous Condenser

The power factor can also be correct by installing the specially designed induction motor, known as the synchronous condenser. The synchronous condenser was running without the mechanical load, and it is connected in parallel with the load. It absorbs and generates the reactive power (Var)  by varying the excitation of the motor field winding.
The synchronous condenser is used for improving the power factor in bulk. The output of the phase modifier can be varied smoothly. The synchronous condenser has some disadvantage like it is costly and their installation, maintenance and operation are also not easy.

Power Factor Improvement

Power Factor Improvement

If the power factor is low or poor, it is necessary to improve or correct it. It may be improved by injecting a leading current into the circuit so as to neutralize the effect of lagging current. The power factor may be improved by using static capacitors or synchronous motors.

Power factor correction by static capacitors

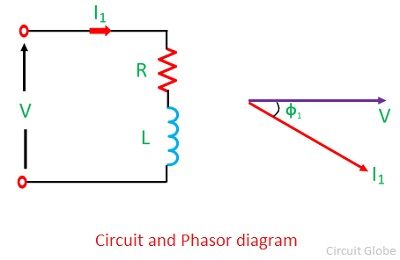
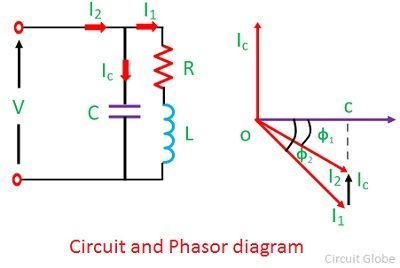
Consider an inductive load consisting of a resistor R and an inductor L connected to an AC supply. The circuit and phasor diagrams are shown in the figure.
power-factor-improvemet-1Let,
V – supply voltage.
I1 –  load current
φ1 – phase angle by which the current I1 lags behind the voltage
cosφ1 – original power factor
Let the capacitor C be placed in parallel with the load. It will take a leading current  Ic  from the supply. The circuit and phasor diagrams are shown in the figure.
power-factor-improvement-2
The total I2 drawn from the supply will be equal to the phasor sum of I1 and Icthat is

power-factor-improvement-equation-1Conclusions

  • The phase angle of I2 is φ2. It is seen from the phasor diagram that the φ2 is less than φ1, and hence, cosφ2 is greater than cosφ1. In other words, the power is improved from cosφ1 to cosφ2.
  • The new current supply from the supply is less than the load current I1, i.e., I2> I1. The new current is given by the equation
power-factor-improvement-3
  • By connecting a capacitor in parallel with an inductive load, the power factor is improved, and the current from the supply is reduced without altering either current or power taken by the load.
power-system-improvement-3This relation shows that the power taken from the supply has not altered.

Static VAR Compensator

Static VAR Compensator

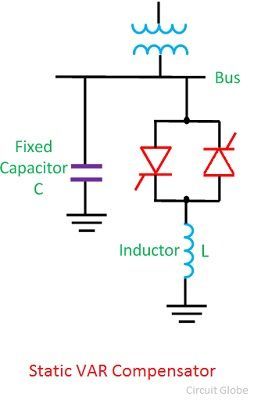
A static VAR compensator is a parallel combination of controlled reactor and fixed shunt capacitor shown in the figure below. The thyristor switch assembly in the SVC controls the reactor. The firing angle of the thyristor controls the voltage across the inductor and thus the current flowing through the inductor. In this way, the reactive power draw by the inductor can be controlled.
static-var-compensator-compressor(1)The SVC is capable of step less adjustment of reactive power over an unlimited range without any time delay. It improves the system stability and system power factor. Most commonly used SVC scheme are as follows.
  1. Thyristor controlled reactor (TCR)
  2. Thyristor-switched capacitor (TSC)
  3. Self Reactor (SR)
  4. Thyristor controlled reactor – Fixed capacitor (TCR-FC)
  5. Thyristor-switched capacitor – Thyristor controlled reactor (TSC-TCR)

Advantage of Static VAR Compensator

  • It increased the power transmission capability of the transmission lines.
  • It improved the transient stability of the system.
  • It controlled the steady state and temporary overvoltages.
  • It improved the load power factor, and therefore, reduced line losses and improved system capability.
Static VAR compensator has no rotating parts and is employed for surge impedance compensation and compensation by sectionalizing a long transmission line.

Methods of Voltage Control in Power System

Methods of Voltage Control in Power System

The voltage of the power system may vary with the change in load. The voltage is normally high at light load and low at the heavy-load condition. For keeping the voltage of the system in limits, some additional equipment requires which increase the system voltage when it is low and reduces the voltage when it is too high. The following are the methods used in the power system for controlling the voltage.
  1. On – Load Tap Changing Transformer
  2. Off – Load Tap Changing transformer
  3. Shunt Reactors
  4. Synchronous Phase Modifiers
  5. Shunt Capacitor
  6. Static VAR System (SVS)
Controlling the system voltage by the help of shunt inductive element is known as shunt compensation. The shunt compensation is of two types, i.e., the static shunt compensation and the synchronous compensation. In static shunt compensation, the shunt reactor, shunt capacitor and static VAR system are used, whereas the shunt compensation uses the synchronous phase modifier. The methods used for controlling the voltage are explained below in details.
1. Off – Load Tap Changing Transformer – In this method, the voltage is controlled by changing the turn ratio of the transformer. The transformer is disconnected from the supply before changing the tap. The tap changing of the transformer mostly done manually.
2. On – Load Tap Changing Transformer – This arrangement is used for changing the turn ratio of the transformer for regulating the system voltage when the transformer delivers the load. Most of the power transformer is provided with on-load tap changer.
3. Shunt Reactor – The shunt reactor is the inductive current element which is connected between the line and neutral. The shunt reactor compensates the inductive current from the transmission line or underground cables. It is mainly used in the long distance EHV and UHV transmission lines for reactive power control.
The shunt reactors are used in the sending end substation, receiving end substation and in the intermediate substation of long EHV and UHV line. In the long transmission line, the shunt reactor is connected at the distance of 300 Km to limit the voltage at an intermediate point.
4. Shunt Capacitors – The shunt capacitors are the capacitors connected in parallel with the line. It is installed at the receiving end substation, distribution substations and in the switching substations. The shunt capacitor injected the reactive volt-ampere to the line. It is placed in the three phase bank.
5. Synchronous Phase Modifier – The synchronous phase modifier is the synchronous motor running without a mechanical load. It is connected with the load at receiving the end of the line. The synchronous phase modifier absorbs or generates the reactive power by varying the excitation of the field winding. It keeps the voltage constant at any condition of the load and also improves the power factor.
6. Series Var Systems (SVS) – The static VAR compensator inject or absorb the inductive VAR to the system when the voltage becomes higher or lower than the reference value. In static VAR compensator, the thyristor is used as switching device in place of circuit breakers. Nowadays, the thyristor switching is used in the system in place of mechanical switching because thyristor switching is faster and provides transient free operation by controlling the switching.

Magnetic Hysteresis

Magnetic Hysteresis

The phenomenon of flux density B lagging behind the magnetizing force H in a magnetic material is known as Magnetic Hysteresis. The word Hysteresis is derived from the Greek word Hysterein means to lag behind. In other words, when the magnetic material is magnetized first in one direction and then in the other direction, completing one cycle of magnetization, it is found that the flux density B lags behind the applied magnetization force H.
There are various types of magnetic materials such as paramagnetic, diamagnetic, ferromagnetic, ferromagnetic and antiferromagnetic materials. Ferromagnetic materials are mainly responsible for the generation of the hysteresis loop.
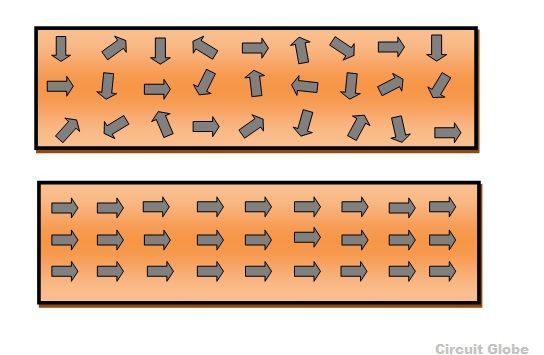
ferromagnetic-materialWhen the magnetic field in not applied the ferromagnetic material behaves like a paramagnetic material. This means that at the initial stage the dipole of the ferromagnetic material is not aligned, they are randomly placed. As soon as the magnetic field is applied to the ferromagnetic material, its dipole moments align themselves in one particular direction as shown in the above figure, resulting in a much stronger magnetic field.
Contents:
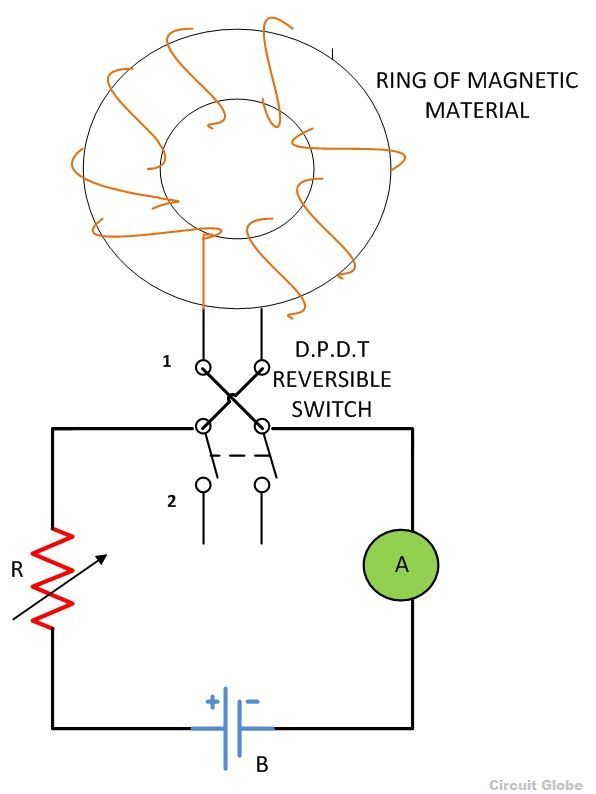
For understanding the phenomenon of the magnetic hysteresis, consider a ring of magnetic material wound uniformly with solenoid. The solenoid is connected to a DC source through a Double pole double throw (D.P.D.T) reversible switch as shown in the figure below
hysteresis-loop-circuit-diagram
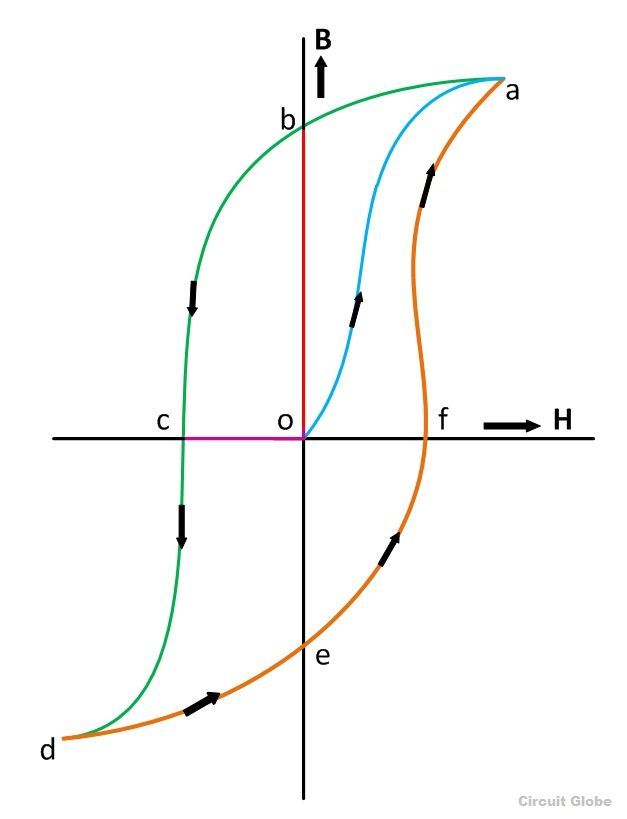
Initially, the switch is in position 1. By decreasing the value of R the value of the current in the solenoid increases gradually resulting in a gradual increase in field intensity H, the flux density also increases till it reaches the saturation point a and the curve obtained is oa. Saturation occurs when on increasing the current the dipole moment or the molecules of the magnet material align itself in one direction.
Now by decreasing the current in the solenoid to zero the magnetizing force is gradually reduced to zero, but the value of flux density will not be zero as it still has the value ob when H=0, so the curve obtained is ab as shown in the figure below.This value ob of flux density is because of the residual magnetism.
magnetic-hysteresis-loop

Residual Magnetism

The value of the flux density ob retained by the magnetic material is called residual magnetism, and the power of retaining it is known as Retentivity of the material.
Now to demagnetize the magnetic ring, the position of the D.P.D.T reversible switch is changed to position 2 and thus, the direction of flow of the current in the solenoid is reversed resulting in reverse magnetizing force H. When H is increased in reverse direction, the flux density starts decreasing and becomes zero (B=0) and the curve shown above follows the path bc. The residual magnetism of the material is removed by applying the magnetizing force known as Coercive force in the opposite direction.

Coercive Force

The value of the magnetizing force oc required to wipe out the residual magnetism ob is called Coercive force shown by pink color in the hysteresis curve shown above.
Now to complete the hysteresis loop the magnetizing force H is further increased in the reverse direction till it reaches the saturation point d but in the negative direction, the curve traces the path cd. The value of H is reduced to zero H=0 and the curve obtains the path de, where oe is residual magnetism when the curve is in the negative direction.
The position of the switch is changed to 1 again from the position 2 and the current in the solenoid is again increased as done in the magnetization process and due to this H is increased in the positive direction tracing the path as efa, and finally the hysteresis loop is complete. In the curve again of is the magnetizing force, also known as the Coercive force required to remove the residual magnetism oe.
Here the total Coercive force required to wipe off the residual magnetism in one complete cycle is denoted by cf. From the above discussion, it is clear that the flux density B always lags behind the magnetizing force H. Hence the loop ‘abcdefa’ is called the Magnetic Hysteresis loop or Hysteresis Curve.
Magnetic hysteresis results in the dissipation of wasted energy in the form of heat. The energy wasted is proportional to the area of the magnetic hysteresis loop. Mainly there are two types of magnetic material, soft magnetic material and hard magnetic material.

Soft magnetic material
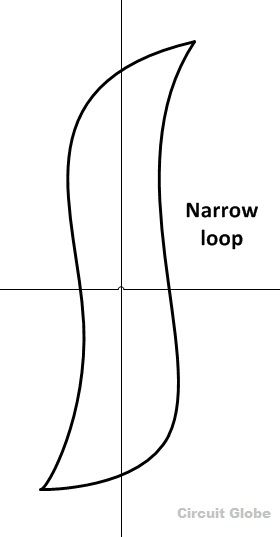
The soft magnetic material has a narrow magnetic hysteresis loop as shown in the figure below which has a small amount of dissipated energy. They are made up of material like iron, silicon steel, etc.
soft-magnetic-material-loop
Soft Magnetic Material Loop
  • It is used in the devices that require alternating magnetic field.
  • It has low coercivity
  • Low magnetization
  • Low retentivity

Hard magnetic material
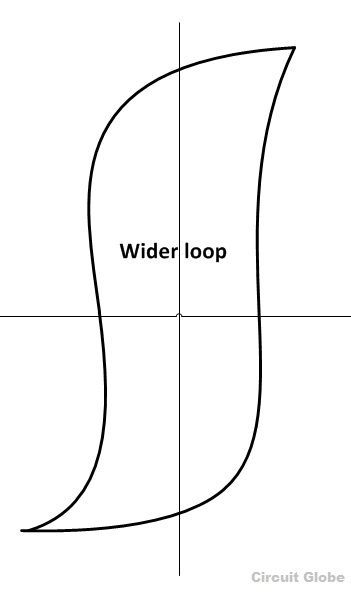
The Hard magnetic material has a wider hysteresis loop as shown in the figure below and results in a large amount of energy dissipation and the demagnitisation process is more difficult to achieve.
hard-magnetic-material
Hard Magnetic Material Loop
  • It has high retentivity
  • High coercivity
  • High saturation

Applications of Magnetic Hysteresis
  • Magnetic material having a wider hysteresis loop is used in the devices like magnetic tape, hard disk, credit cards, audio recordings as its memory is not easily erased.
  • Magnetic materials having a narrow hysteresis loop are used as electromagnets, solenoid, transformers and relays which require minimum energy dissipation.

Advantages of 3 Phase Over Single Phase System

Advantages of 3 Phase Over Single Phase System The three-phase system has three live conductors which supply the 440V to the large consu...